ROBEX Technology
AXIS is the intelligent software architecture that powers every ROBEX platform. It integrates missions, platforms, and payloads into a unified autonomous system for industrial and enterprise operations.
AXIS Control Center
Active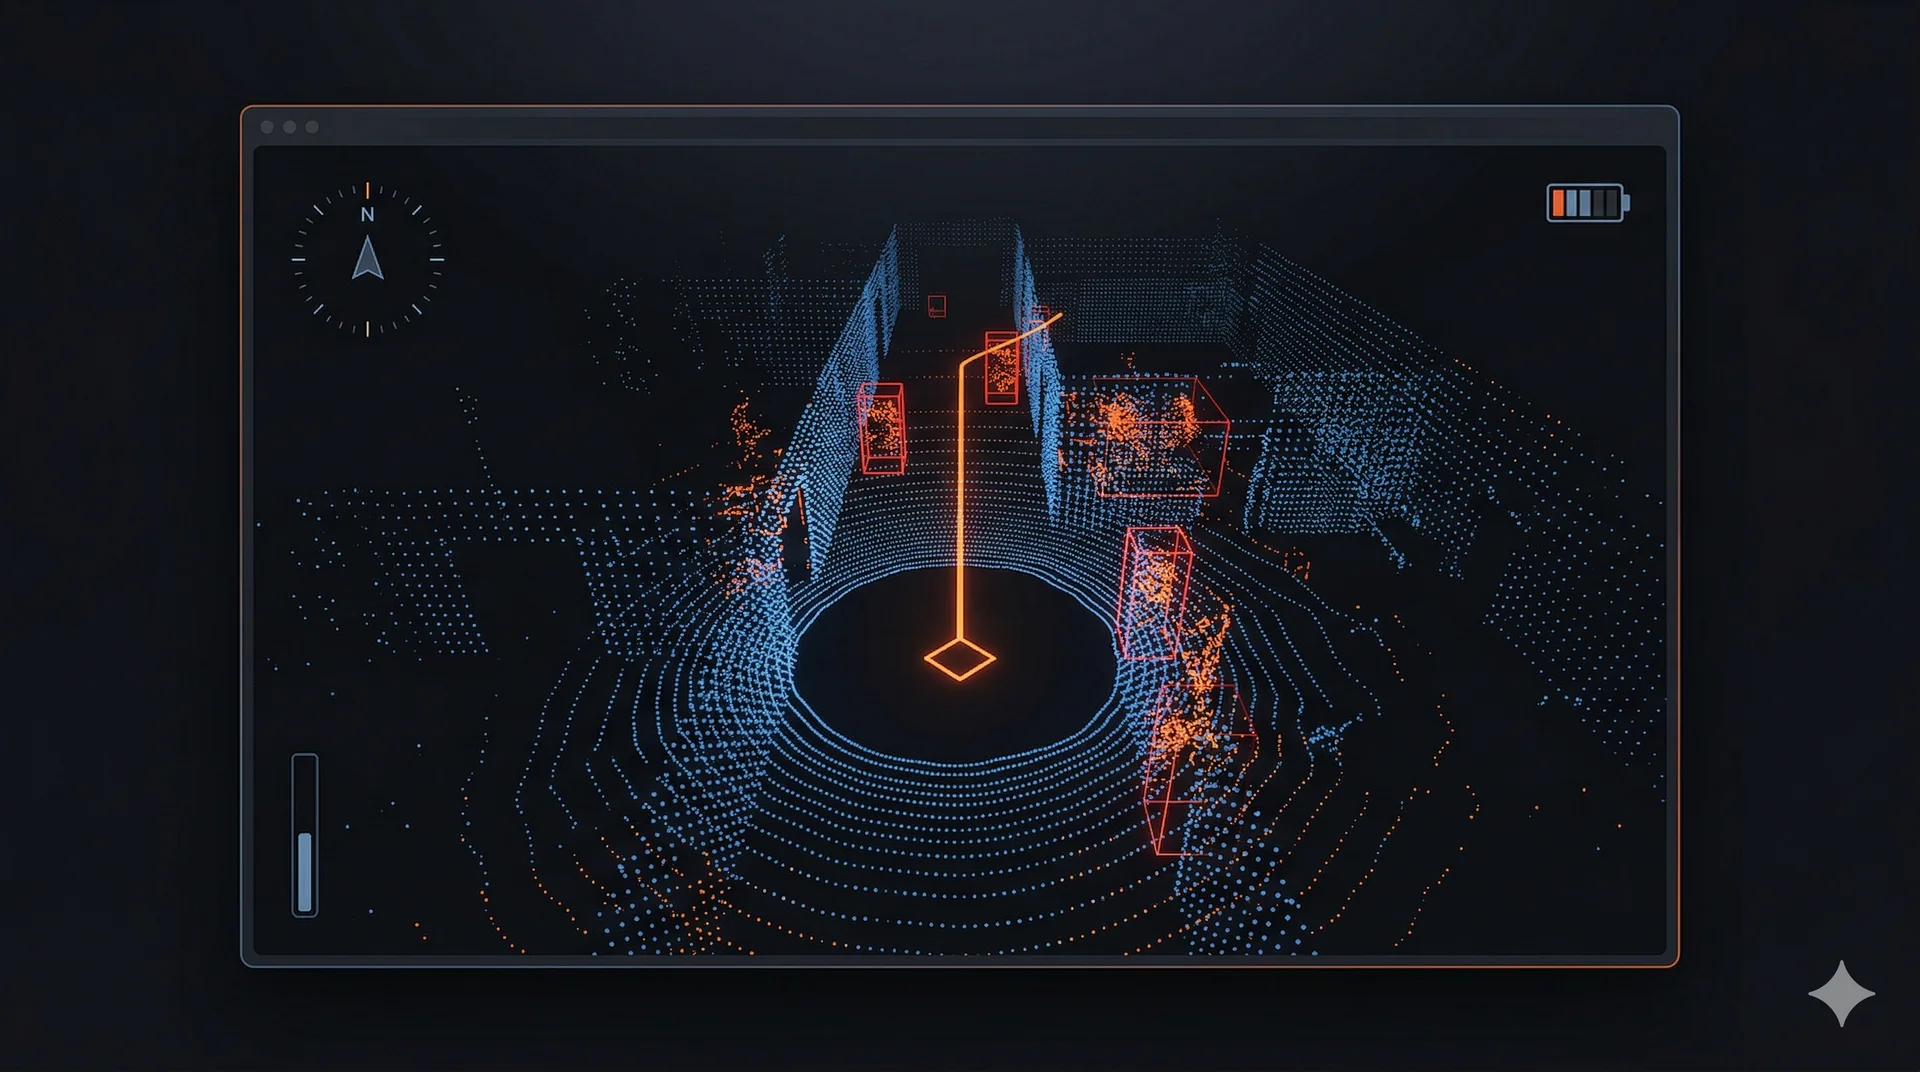
Every ROBEX platform runs on AXIS. It is not an add-on or an interface layer. It is the system that makes autonomous operation possible. Without AXIS, a robot moves. With AXIS, it thinks, navigates, collects, and reports.
What AXIS does
Autonomous Navigation
Autonomous operation in GPS-denied, confined and structurally complex environments. Sensor fusion from GNSS, IMU and onboard cameras keeps positioning and path execution accurate without continuous operator input.
Real-Time Data Streaming
Thermal, gas, visual, radiation and particulate readings are processed onboard and streamed live to the operator interface. Every reading is timestamped, geolocated and logged automatically.
Fleet Management
Multiple units across one site or several locations are managed from a single interface. Mission assignment, status monitoring and data aggregation happen from one dashboard, with no per-unit configuration overhead.
Mission Logging & Export
Every mission is recorded in full — route taken, sensor readings, anomalies flagged, operator actions. Data exports in standard formats for compliance documentation, post-mission analysis or existing operational systems.
Enterprise Integration
AXIS connects to existing infrastructure over RESTful and gRPC APIs — SCADA, security management platforms or a custom data pipeline. It is designed to work within the operational environment, not alongside it.
AXIS control unit
The onboard intelligence layer embedded in every ROBEX platform. It handles communication, motor control, positioning and data processing in a compact, industrially hardened form factor.
- System infrastructure
- Industrial Linux — custom control board
- Power input
- 12 V DC · typical 10–15 W, max 36 W
- Motor outputs
- 2 × 12 V DC — 8 A PWM per channel
- Connectivity — Ethernet
- 4 × LAN ports
- Connectivity — USB
- 4 × USB ports
- Connectivity — Serial
- 1 × CANbus · RS485
- Positioning
- 72-channel GNSS + 6-axis IMU
- Dimensions
- 367.5 × 282.25 × 44.45 mm · 3.2 kg
- With mounting bracket
- 494.5 × 282.25 × 44.45 mm
Connector layout
The rear panel provides direct access to all I/O interfaces. Each connector has a fixed function.
- J1 / J2
- PWM out 1–2
- J3 / J4 / J5
- AC CNT 1–3
- J6
- CANbus
- J7
- RS485
- J8 / J9
- RF
- J10
- Power input
- ETH 1–4
- LAN Ethernet switch
- ETH 5 / PC ETH
- Uplink / PC Ethernet
- USB 3.0 / 2.0
- USB host ports
Protocol compatibility
AXIS supports the full range of industrial motor and communication protocols, so existing actuators, sensors and control systems integrate without protocol conversion hardware.
Standard for automotive and robotics control systems
Real-time Ethernet for precision motion control
Direct motor drive, servo and ESC compatible
Industrial automation and SCADA integration
Distributed control in industrial networks
Siemens and industrial automation ecosystem
Heavy vehicle and off-road machinery integration
Who AXIS is built for
- Industrial operators integrating ROBEX into existing SCADA and control infrastructure
- Security operators managing multi-unit patrol deployments from a single interface
- Mining and inspection teams requiring timestamped, auditable sensor data for compliance
- Engineering and R&D teams developing algorithms on a real, field-ready autonomous platform
- Defence and civil protection units requiring reliable autonomous operation in contested environments
For developers
AXIS exposes a full API surface for teams integrating ROBEX into custom workflows or building mission-specific applications. RESTful and gRPC endpoints provide access to navigation control, sensor data streams, fleet status and mission logging.
ROS 2 compatible. Documentation available on request.
Request API documentationReady to deploy?
Let's discuss how ROBEX can transform your operations with intelligent robotic solutions tailored to your mission.